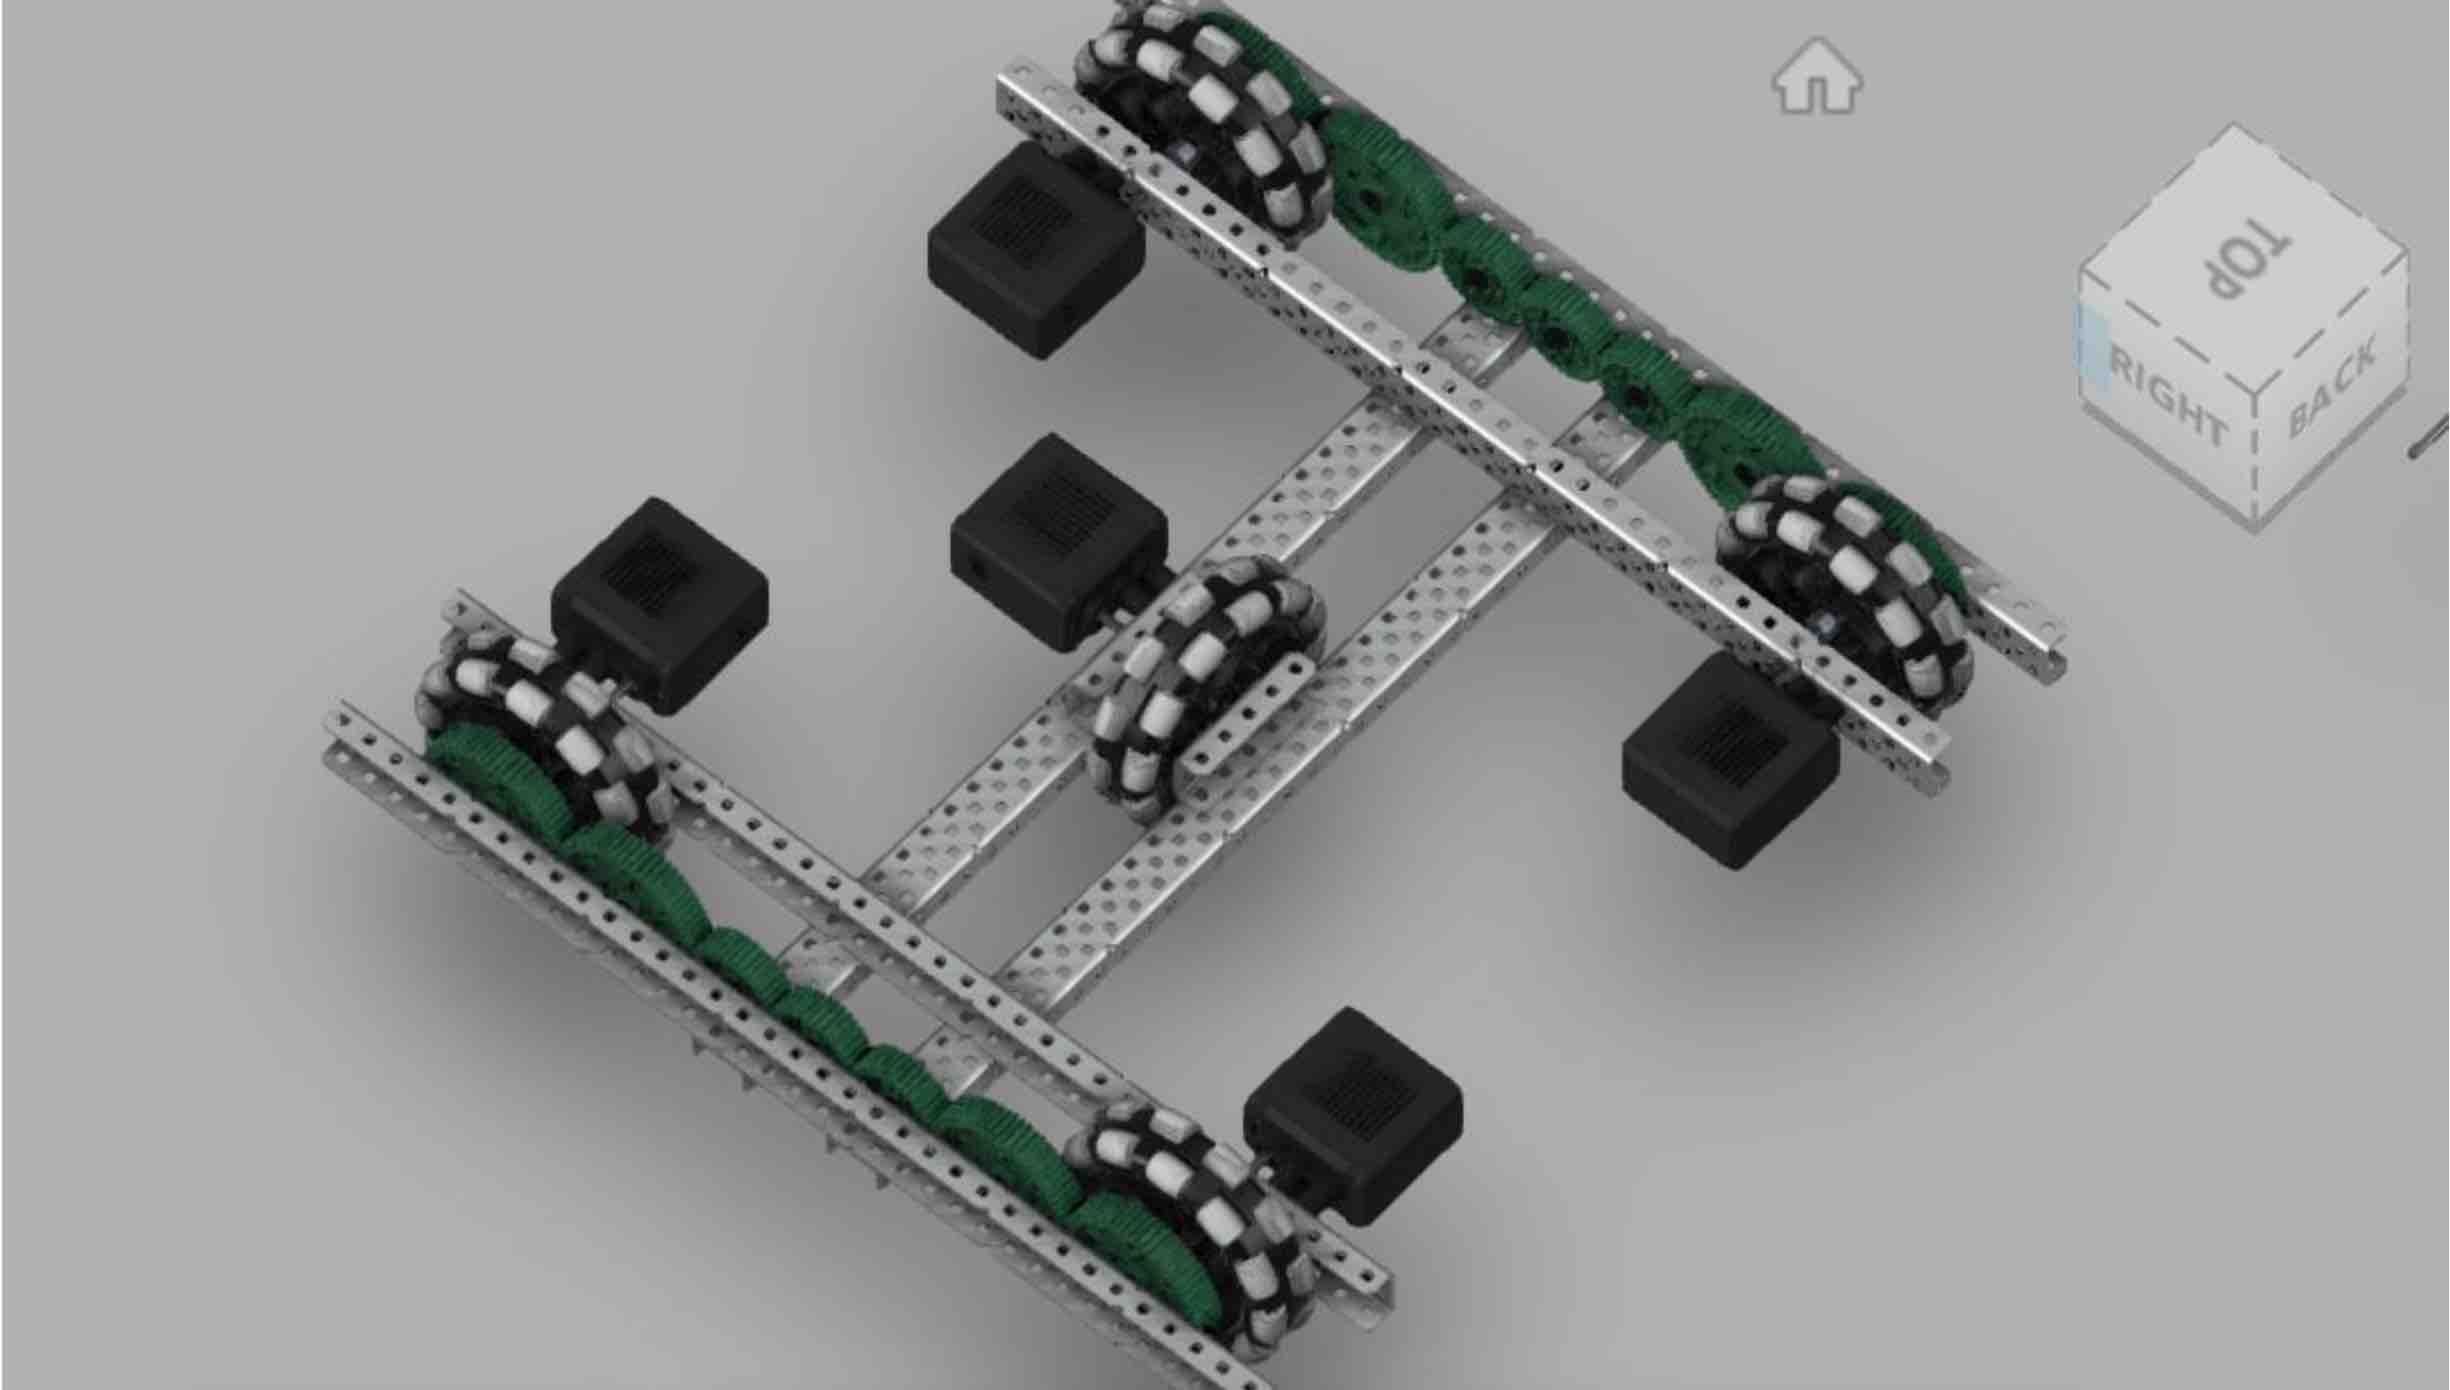
H drivetrain researching
By Maplerobot
Pros of the H-drive
Due to its additional support systems, which make it more robust and balanced than other drive trains, it is first and foremost significantly more stable and simple to manage than the X-drive.This implies that it can move around during the autonomous phase more steadily. The wheel in the centre gives it greater manoeuvrability than the tank drive. The extra wheel serves as a pivot, enhancing the H-drive’s ability to turn with greater agility. The positioning of the wheels also helps to reduce friction when turning, resulting in smoother turning and lessening wheel wear and tear. It will be particularly effective throughout the autonomous phase because it is very stable. There would only be minor differences, and changes in direction.
Cons of the H-drive
First of all the design of the H-drive is very complex, this is because of the unique arrangement of the wheels and the additional support mechanisms which make the design more complex than other drive trains. The H-drive is also quite heavy because of how complex it is. The additional support mechanisms add a lot of weight onto the drive train. The additional moving parts would increase the risk of mechanical failure. Components like the center wheel, the support mechanisms would need more inspection than other parts as a result. The H-drive also does not have as much standardization compared to other drive trains. This would make it harder to find components of the H-drive off the shelf. After discussing and looking at the 3d model that we built. We found out that he H-drive would not be able to cross the barrier because the additional wheel in the middle which blocks it from passing the barrier. Therefore we decided to not use the H-drive.
Next Steps
After abandoning the idea of an H-drive we decided to try and use a tank drive. Our 3d design of the tank drive will be similar to the H-drive but will not have the middle wheel. As a result of not having the middle wheel our tank drive will be able to cross the middle barrier but still retain some of the pro’s from the H-drive. The tank drive would be stable and versatile like the X-drive but it would be able to cross the middle pipe barrier and would not have the wheel in the middle. If the tank drive does not work we will change our drive train back to an X-drive