Tank drivetrain researching
By Maplerobot
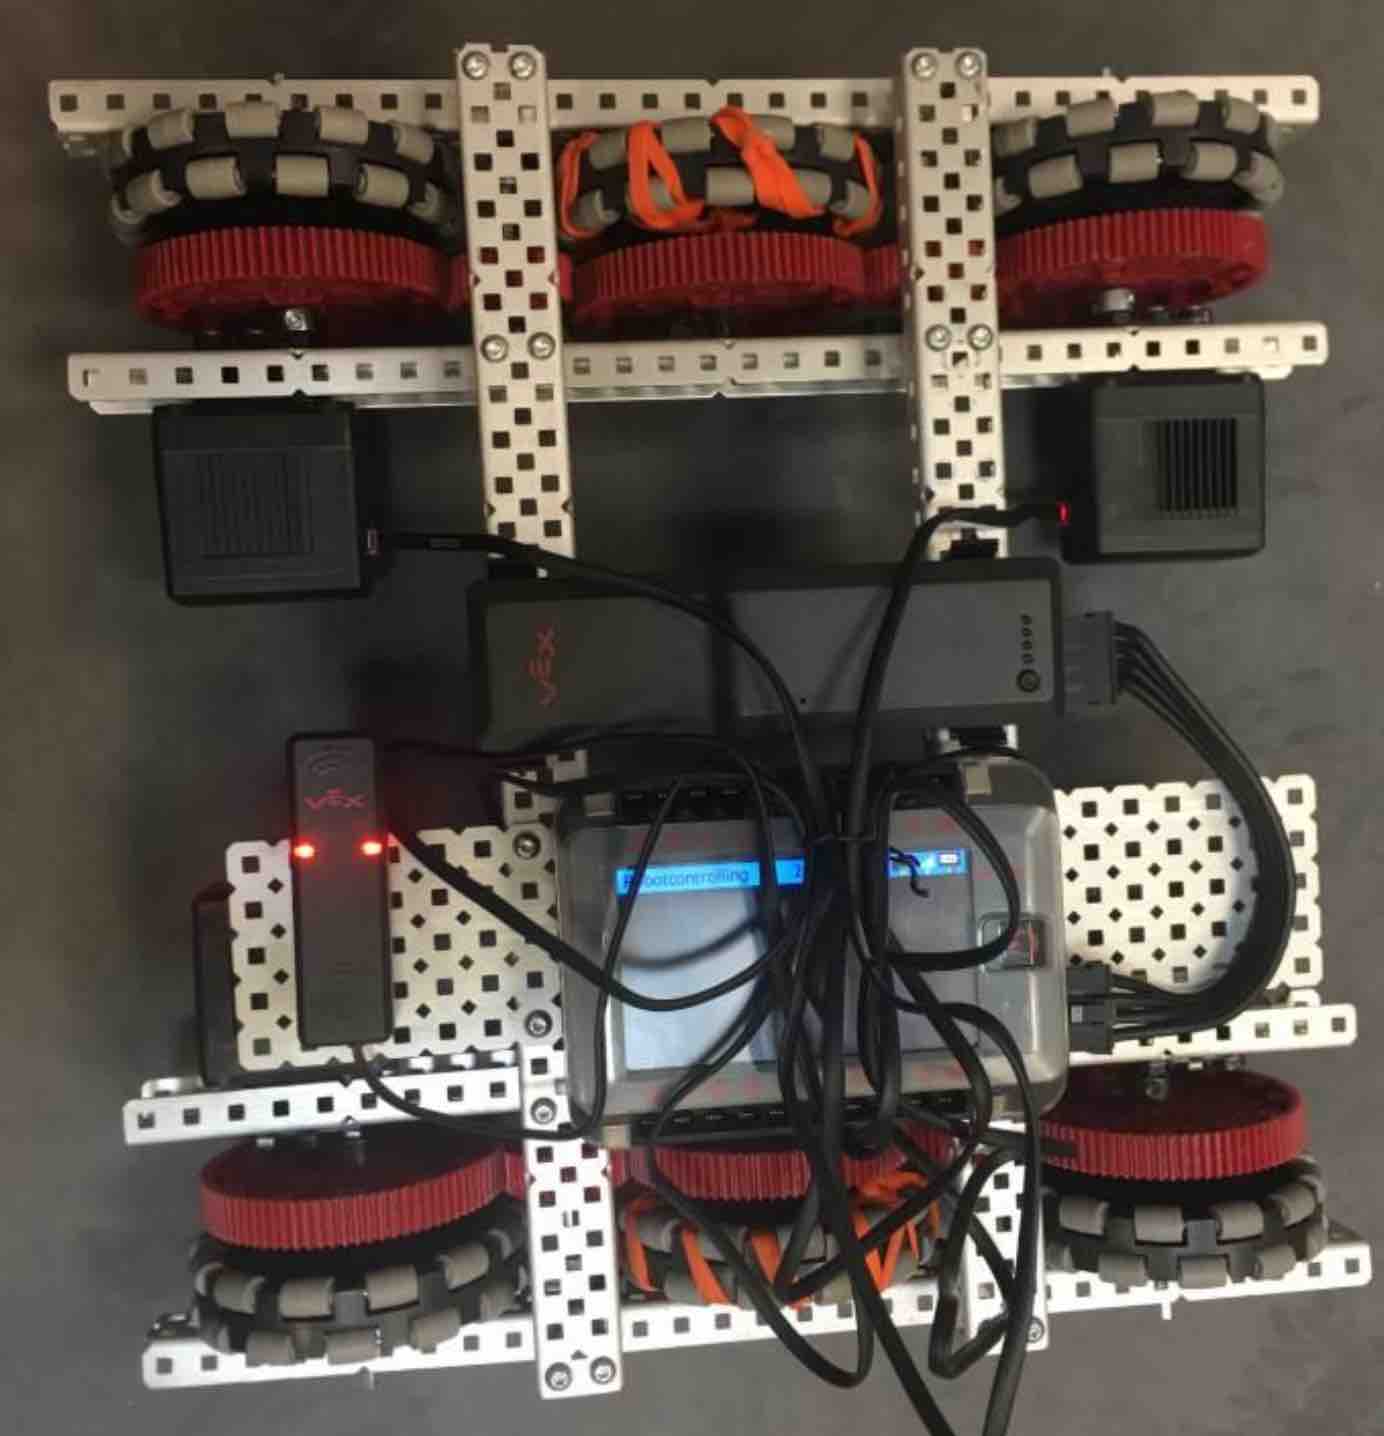
After deciding that the Mecanum drive was not suitable for this mission, we decided to change to the Tank drive. We made a 3d model on Fusion 360 and we debated about where the six wheels would be used in our drivetrain. Eventually we settled on 4 omni wheels that are placed on the corners of the drivetrain because it would be able to turn easier and we put friction wheels in the middle because wheels in the middle can turn easier. The friction wheels in the middle would grip on the ground and as a result would increase acceleration and speed.
Pro’s of the Tank drive
By having four omni wheels and two traction wheels we found out that the the tank drive will have high forwards traction because of the traction wheel and it will also have high horizontal traction because of the four omni directional wheels but the traction wheels will also grip onto the floor.Which would make it harder to push since the traction wheels increase the friction. There will also be reduced compression because of the six wheels. But we found out that it is very simple and easy to build and it still has many advantages so that is why we decided to build the tank drive.
Cons of the tank drive
The six wheel tank drive is heavier because of the extra wheels, it also has lower maneuverability because of the gears. It also has no sideways movement because it does not have a wheel in the middle like that H-drive does. So therefore the tank drive can only move front, back and turn but it cannot go sideways. The tank drive is also slower than the X-drive because of the weight and the wheels are connected by gears.
Next steps
We are going to work on the claw and arm next because we are finished our drivetrain so we need to build an intake and shooting mechanism so we can collect and shoot the triballs. We might also use our arm to grab the pole and lift our robot up, but for now we are going to focus on making the arm grab the triballs and throw the triballs.
Problem with the Tank drive
After we finished building the Tank drive we realized that our middle wheels which are traction wheels were not touching the ground. As a result, the purpose of the wheels which was to increase friction would not work. We added the traction wheels to increase the friction so that we wouldn’t get pushed sideways easily. The reason why the middle traction wheels were not on the ground was because the omni-directional wheels that we used were larger than the traction wheel.